01
Multi-node
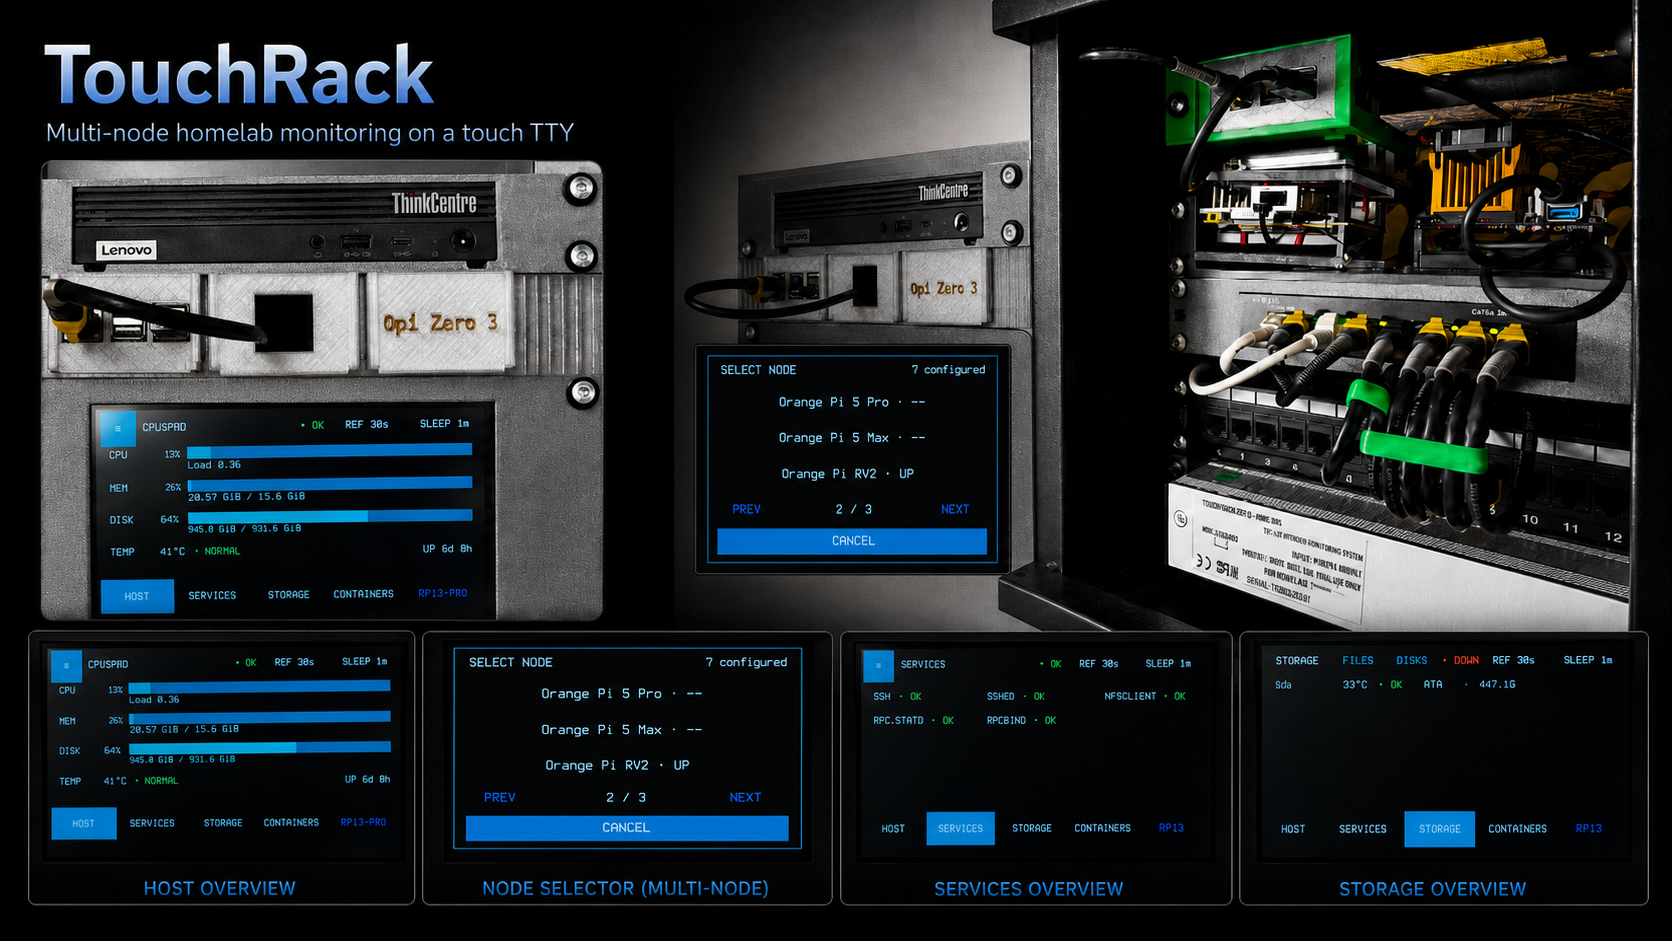
A single panel can select and monitor the local host and remote Linux nodes. Remote nodes do not require a TouchRack agent and are queried through a constrained SSH transport.
Project
A touch-first, multi-node homelab console designed specifically for physical displays attached to a Linux TTY, with no X11, Wayland, browser or desktop environment required.
TouchRack turns a small touchscreen directly attached to a Linux system into a dedicated monitoring console. The interface is designed around the constraints of a physical console and can monitor both the local host and multiple remote Linux nodes from a single touch-first interface.
A single panel can select and monitor the local host and remote Linux nodes. Remote nodes do not require a TouchRack agent and are queried through a constrained SSH transport.
CPU, memory, storage, temperature, disk health and containers are exposed through views designed around the limited space of the physical console.
Important services are explicitly curated and normalized into common states regardless of whether they originate from CRUX, systemd, containers, HTTP or TCP.
Touch input is read directly through evdev. Display sleep handling includes a wake guard so the first touch wakes the panel without accidentally activating the control underneath.
The interface is designed around a physical touchscreen and compact Linux console rather than being a desktop application later adapted to one.
TouchRack separates presentation from data collection so the interface does not need to know how each monitored resource is obtained.
The interface is built with Textual and includes a dedicated compact layout for small terminals such as the reference 64×18 physical console.
Each node is represented through a common identity, runtime and transport used by the different monitoring capabilities.
Host, storage, SMART, containers and services use independent providers that transform different information sources into models consumed by the interface.
The same model can query the local system or execute defined read-only commands on remote nodes through OpenSSH.
Transport failures retain the last successful information as STALE while a shared circuit breaker prevents redundant SSH connections while a node remains unavailable.
TouchRack is designed as an observation surface. Monitoring failures degrade the displayed state instead of turning the console into a generally privileged administration interface.
The reference deployment runs TouchRack as a systemd service on a dedicated TTY through openvt. The runtime is installed independently under /opt/touchrack while configuration is kept under /etc/touchrack.